
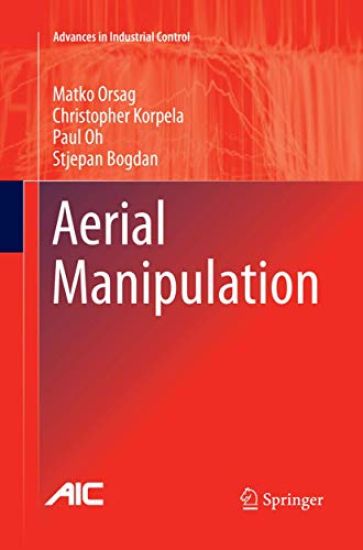
Aerial Manipulation – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9783319869865 (nidottu).
Muut painokset ja formaatit
Kirjan kuvaus
This text is a thorough treatment of the rapidly growing area of aerial manipulation. It details all the design steps required for the modeling and control of unmanned aerial vehicles (UAV) equipped with robotic manipulators. Starting with… Näytä koko kuvaus Piilota kuvaus
This text is a thorough treatment of the rapidly growing area of aerial manipulation. It details all the design steps required for the modeling and control of unmanned aerial vehicles (UAV) equipped with robotic manipulators. Starting with the physical basics of rigid-body kinematics, the book gives an in-depth presentation of local and global coordinates, together with the representation of orientation and motion in fixed- and moving-coordinate systems. Coverage of the kinematics and dynamics of unmanned aerial vehicles is developed in a succession of popular UAV configurations for multirotor systems. Such an arrangement, supported by frequent examples and end-of-chapter exercises, leads the reader from simple to more complex UAV configurations. Propulsion-system aerodynamics, essential in UAV design, is analyzed through blade-element and momentum theories, analysis which is followed by a description of drag and ground-aerodynamic effects. The central part of the book is dedicated to aerial-manipulator kinematics, dynamics, and control. Based on foundations laid in the opening chapters, this portion of the book is a structured presentation of Newton–Euler dynamic modeling that results in forward and backward equations in both fixed- and moving-coordinate systems. The Lagrange–Euler approach is applied to expand the model further, providing formalisms to model the variable moment of inertia later used to analyze the dynamics of aerial manipulators in contact with the environment. Using knowledge from sensor data, insights are presented into the ways in which linear, robust, and adaptive control techniques can be applied in aerial manipulation so as to tackle the real-world problems faced by scholars and engineers in the design and implementation of aerial robotics systems. The book is completed by path and trajectory planning with vision-based examples for tracking and manipulation.
Kirjan tiedot
Vertaa kirjan ”Aerial Manipulation” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9783319869865.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Aerial Manipulation – hintahistoria
Seuraamme kirjan Aerial Manipulation hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.