
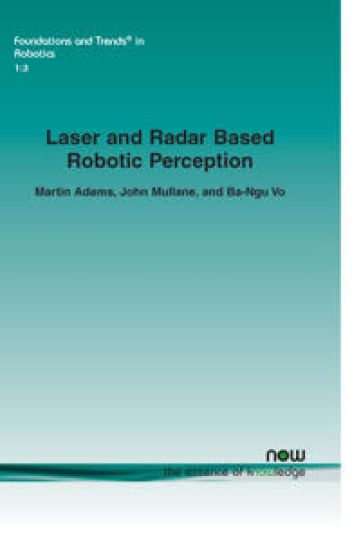
Laser and Radar Based Robotic Perception – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9781601984722 (nidottu).
Kirjan kuvaus
A crucial component of perception is the understanding of information which has passed through a sensor's detection process. In the world of autonomous robotics this takes the form of sensor understanding and modelling, feature detection,… Näytä koko kuvaus Piilota kuvaus
A crucial component of perception is the understanding of information which has passed through a sensor's detection process. In the world of autonomous robotics this takes the form of sensor understanding and modelling, feature detection, predicting measurements/observations, feature matching and sensor data representation. Laser and Radar Based Robotic Perception presents a review of autonomous robotic perception, exploring recent work from the autonomous robotics and tracking communities in general as well as from the authors' own experiences. Throughout the text, experiments and results are derived from the authors' experiences with laser and radar based sensors. The concepts used in the experiments, and conclusions drawn from them, are then compared with state of the art perception methods in a review type fashion. The book also reviews and presents methods which cope probabilistically with missed detections (the possibility of a sensor not detecting an object of interest), object spatial uncertainty (in which detected objects are given uncertain range and/or bearing values due to sensor noise) and false alarms (the possibility of a sensor reporting a detection, due to noise, when in fact nothing (or nothing of interest) is present). Environment measurement models based on these phenomena are therefore analysed. A further concept, often over-looked in the robotic, but apparent in the tracking literature, is that of estimating the correct number of features in an environment. Recent work which advocates the joint estimation of map features with respect to their number as well as location is reviewed.
Kirjan tiedot
Vertaa kirjan ”Laser and Radar Based Robotic Perception” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9781601984722.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Laser and Radar Based Robotic Perception – hintahistoria
Seuraamme kirjan Laser and Radar Based Robotic Perception hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.