
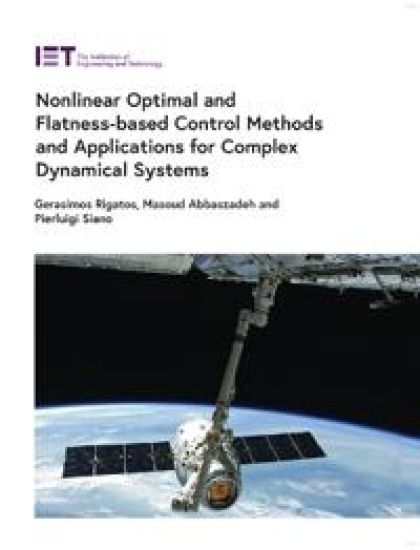
Nonlinear Optimal and Flatness-based Control Methods and Applications for Complex Dynamical Systems – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9781839538193 (sidottu).
Kirjan kuvaus
Robotics, mechatronics and autonomous systems can exhibit complex nonlinear dynamics which can lead to unsatisfactory transients and deviation from setpoints or even to instability. A standard approach in the control of these systems had… Näytä koko kuvaus Piilota kuvaus
Robotics, mechatronics and autonomous systems can exhibit complex nonlinear dynamics which can lead to unsatisfactory transients and deviation from setpoints or even to instability. A standard approach in the control of these systems had been the concept of diffeomorphisms to bring a system into a linear form. However, these methods are not straightforward and result in complicated state-space model transformations. In this monograph, new methods have been investigated which are not constrained by the shortcomings of global linearization-based control schemes. They can be implemented in a computationally simple manner, are followed by global stability proofs, and perform better than previous optimal control approaches for a wider class of nonlinear dynamical systems and applications. In this monograph, the authors present two main proven control methods: the nonlinear optimal (H-infinity) control method, and the flatness-based control approach. These methods have shown to be better suited than previous standard approaches in solving control issues, and can be used in a wide class of dynamical systems. They can have a broad range of applications in mechatronics, industrial robotics, space robotics, robotic cranes and pendulums, autonomous vehicles, aerospace systems and satellites, power electronics, biosystems and financial systems. This very comprehensive monograph is a valuable resource for academic researchers and engineers working on control systems and estimation methods, and university staff and graduate students in the fields of control and automation, robotics and mechatronics, electrical engineering, electric power systems and power electronics, biosystems, computer science, financial systems, and physics. The monograph is also a very useful reference for skilled technical professionals developing real world applications.
Kirjan tiedot
Vertaa kirjan ”Nonlinear Optimal and Flatness-based Control Methods and Applications for Complex Dynamical Systems” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9781839538193.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Nonlinear Optimal and Flatness-based Control Methods and Applications for Complex Dynamical Systems – hintahistoria
Seuraamme kirjan Nonlinear Optimal and Flatness-based Control Methods and Applications for Complex Dynamical Systems hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.