
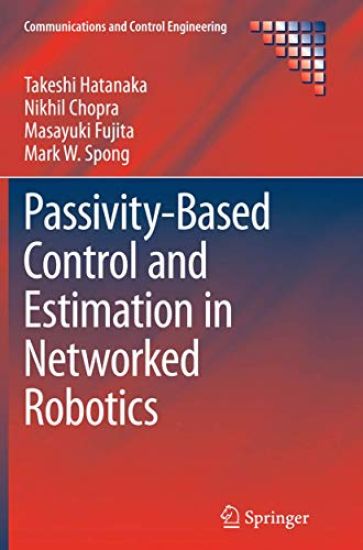
Passivity-Based Control and Estimation in Networked Robotics – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 26 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9783319350400 (nidottu).
Kirjan kuvaus
Highlighting the control of networked robotic systems, this book synthesizes a unified passivity-based approach to an emerging cross-disciplinary subject. Thanks to this unified approach, readers can access various state-of-the-art… Näytä koko kuvaus Piilota kuvaus
Highlighting the control of networked robotic systems, this book synthesizes a unified passivity-based approach to an emerging cross-disciplinary subject. Thanks to this unified approach, readers can access various state-of-the-art research fields by studying only the background foundations associated with passivity. In addition to the theoretical results and techniques, the authors provide experimental case studies on testbeds of robotic systems including networked haptic devices, visual robotic systems, robotic network systems and visual sensor network systems. The text begins with an introduction to passivity and passivity-based control together with the other foundations needed in this book. The main body of the book consists of three parts. The first examines how passivity can be utilized for bilateral teleoperation and demonstrates the inherent robustness of the passivity-based controller against communication delays. The second part emphasizes passivity’s usefulness for visual feedback control and estimation. Convergence is rigorously proved even when other passive components are interconnected. The passivity approach is also differentiated from other methodologies. The third part presents the unified passivity-based control-design methodology for multi-agent systems. This scheme is shown to be either immediately applicable or easily extendable to the solution of various motion coordination problems including 3-D attitude/pose synchronization, flocking control and cooperative motion estimation. Academic researchers and practitioners working in systems and control and/or robotics will appreciate the potential of the elegant and novel approach to the control of networked robots presented here. The limited background required and the case-study work described also make the text appropriate for and, it is hoped, inspiring to students.
Kirjan tiedot
Vertaa kirjan ”Passivity-Based Control and Estimation in Networked Robotics” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9783319350400.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Passivity-Based Control and Estimation in Networked Robotics – hintahistoria
Seuraamme kirjan Passivity-Based Control and Estimation in Networked Robotics hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.