
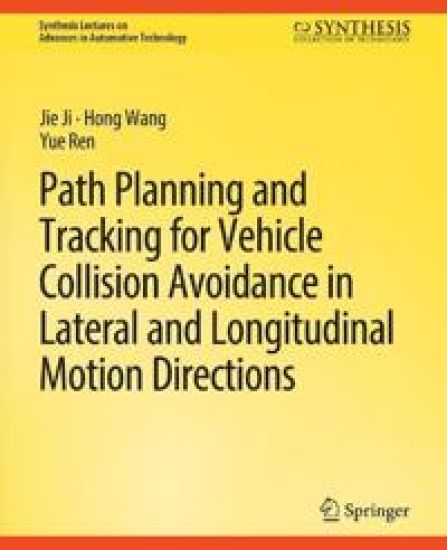
Path Planning and Tracking for Vehicle Collision Avoidance in Lateral and Longitudinal Motion Directions – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9783031003790 (nidottu).
Kirjan kuvaus
In recent years, the control of Connected and Automated Vehicles (CAVs) has attracted strong attention for various automotive applications. One of the important features demanded of CAVs is collision avoidance, whether it is a stationary… Näytä koko kuvaus Piilota kuvaus
In recent years, the control of Connected and Automated Vehicles (CAVs) has attracted strong attention for various automotive applications. One of the important features demanded of CAVs is collision avoidance, whether it is a stationary or a moving obstacle. Due to complex traffic conditions and various vehicle dynamics, the collision avoidance system should ensure that the vehicle can avoid collision with other vehicles or obstacles in longitudinal and lateral directions simultaneously. The longitudinal collision avoidance controller can avoid or mitigate vehicle collision accidents effectively via Forward Collision Warning (FCW), Brake Assist System (BAS), and Autonomous Emergency Braking (AEB), which has been commercially applied in many new vehicles launched by automobile enterprises. But in lateral motion direction, it is necessary to determine a flexible collision avoidance path in real time in case of detecting any obstacle. Then, a path-tracking algorithm is designedto assure that the vehicle will follow the predetermined path precisely, while guaranteeing certain comfort and vehicle stability over a wide range of velocities. In recent years, the rapid development of sensor, control, and communication technology has brought both possibilities and challenges to the improvement of vehicle collision avoidance capability, so collision avoidance system still needs to be further studied based on the emerging technologies. In this book, we provide a comprehensive overview of the current collision avoidance strategies for traditional vehicles and CAVs. First, the book introduces some emergency path planning methods that can be applied in global route design and local path generation situations which are the most common scenarios in driving. A comparison is made in the path-planning problem in both timing and performance between the conventional algorithms and emergency methods. In addition, this book introduces and designs an up-to-date path-planning method based on artificial potential field methods for collision avoidance, and verifies the effectiveness of this method in complex road environment. Next, in order to accurately track the predetermined path for collision avoidance, traditional control methods, humanlike control strategies, and intelligent approaches are discussed to solve the path-tracking problem and ensure the vehicle successfully avoids the collisions. In addition, this book designs and applies robust control to solve the path-tracking problem and verify its tracking effect in different scenarios. Finally, this book introduces the basic principles and test methods of AEB system for collision avoidance of a single vehicle. Meanwhile, by taking advantage of data sharing between vehicles based on V2X (vehicle-to-vehicle or vehicle-to-infrastructure) communication, pile-up accidents in longitudinal direction are effectively avoided through cooperative motion control of multiple vehicles.
Kirjan tiedot
Vertaa kirjan ”Path Planning and Tracking for Vehicle Collision Avoidance in Lateral and Longitudinal Motion Directions” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9783031003790.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Path Planning and Tracking for Vehicle Collision Avoidance in Lateral and Longitudinal Motion Directions – hintahistoria
Seuraamme kirjan Path Planning and Tracking for Vehicle Collision Avoidance in Lateral and Longitudinal Motion Directions hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.