
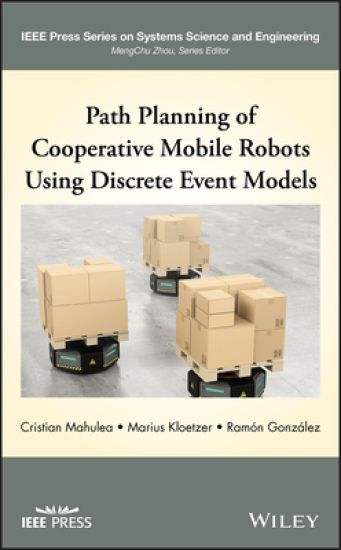
Path Planning of Cooperative Mobile Robots Using Discrete Event Models – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9781119486329 (sidottu).
Kirjan kuvaus
Offers an integrated presentation for path planning and motion control of cooperative mobile robots using discrete-event system principles Generating feasible paths or routes between a given starting position and a goal or target… Näytä koko kuvaus Piilota kuvaus
Offers an integrated presentation for path planning and motion control of cooperative mobile robots using discrete-event system principles Generating feasible paths or routes between a given starting position and a goal or target position—while avoiding obstacles—is a common issue for all mobile robots. This book formulates the problem of path planning of cooperative mobile robots by using the paradigm of discrete-event systems. It presents everything readers need to know about discrete event system models—mainly Finite State Automata (FSA) and Petri Nets (PN)—and methods for centralized path planning and control of teams of identical mobile robots. Path Planning of Cooperative Mobile Robots Using Discrete Event Models begins with a brief definition of the Path Planning and Motion Control problems and their state of the art. It then presents different types of discrete models such as FSA and PNs. The RMTool MATLAB toolbox is described thereafter, for readers who will need it to provide numerical experiments in the last section. The book also discusses cell decomposition approaches and shows how the divided environment can be translated into an FSA by assigning to each cell a discrete state, while the adjacent relation together with the robot's dynamics implies the discrete transitions. Highlighting the benefits of Boolean Logic, Linear Temporal Logic, cell decomposition, Finite State Automata modeling, and Petri Nets, this book also: Synthesizes automatic strategies based on Discrete Event Systems (DES) for path planning and motion control and offers software implementations for the involved algorithmsProvides a tutorial for motion planning introductory courses or related simulation-based projects using a MATLAB package called RMTool (Robot Motion Toolbox)Includes simulations for problems solved by methodologies presented in the book Path Planning of Cooperative Mobile Robots Using Discrete Event Models is an ideal book for undergraduate and graduate students and college and university professors in the areas of robotics, artificial intelligence, systems modeling, and autonomous control.
Kirjan tiedot
Vertaa kirjan ”Path Planning of Cooperative Mobile Robots Using Discrete Event Models” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9781119486329.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Path Planning of Cooperative Mobile Robots Using Discrete Event Models – hintahistoria
Seuraamme kirjan Path Planning of Cooperative Mobile Robots Using Discrete Event Models hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.