
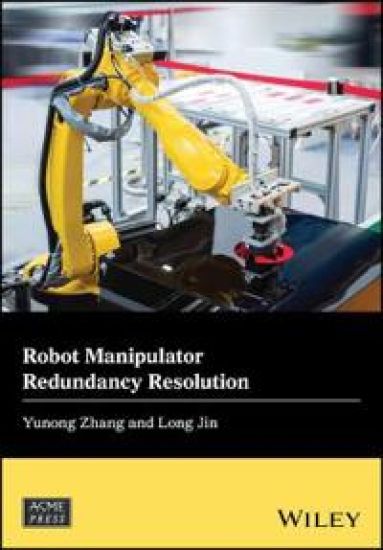
Robot Manipulator Redundancy Resolution – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9781119381235 (sidottu).
Kirjan kuvaus
Introduces a revolutionary, quadratic-programming based approach to solving long-standing problems in motion planning and control of redundant manipulators This book describes a novel quadratic programming approach to solving redundancy… Näytä koko kuvaus Piilota kuvaus
Introduces a revolutionary, quadratic-programming based approach to solving long-standing problems in motion planning and control of redundant manipulators This book describes a novel quadratic programming approach to solving redundancy resolutions problems with redundant manipulators. Known as ``QP-unified motion planning and control of redundant manipulators'' theory, it systematically solves difficult optimization problems of inequality-constrained motion planning and control of redundant manipulators that have plagued robotics engineers and systems designers for more than a quarter century. An example of redundancy resolution could involve a robotic limb with six joints, or degrees of freedom (DOFs), with which to position an object. As only five numbers are required to specify the position and orientation of the object, the robot can move with one remaining DOF through practically infinite poses while performing a specified task. In this case redundancy resolution refers to the process of choosing an optimal pose from among that infinite set. A critical issue in robotic systems control, the redundancy resolution problem has been widely studied for decades, and numerous solutions have been proposed. This book investigates various approaches to motion planning and control of redundant robot manipulators and describes the most successful strategy thus far developed for resolving redundancy resolution problems. Provides a fully connected, systematic, methodological, consecutive, and easy approach to solving redundancy resolution problemsDescribes a new approach to the time-varying Jacobian matrix pseudoinversion, applied to the redundant-manipulator kinematic controlIntroduces The QP-based unification of robots' redundancy resolutionIllustrates the effectiveness of the methods presented using a large number of computer simulation results based on PUMA560, PA10, and planar robot manipulatorsProvides technical details for all schemes and solvers presented, for readers to adopt and customize them for specific industrial applications Robot Manipulator Redundancy Resolution is must-reading for advanced undergraduates and graduate students of robotics, mechatronics, mechanical engineering, tracking control, neural dynamics/neural networks, numerical algorithms, computation and optimization, simulation and modelling, analog, and digital circuits. It is also a valuable working resource for practicing robotics engineers and systems designers and industrial researchers.
Kirjan tiedot
Vertaa kirjan ”Robot Manipulator Redundancy Resolution” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9781119381235.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Robot Manipulator Redundancy Resolution – hintahistoria
Seuraamme kirjan Robot Manipulator Redundancy Resolution hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.