
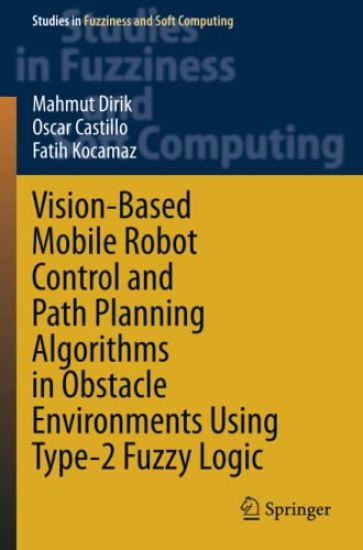
Vision-Based Mobile Robot Control and Path Planning Algorithms in Obstacle Environments Using Type-2 Fuzzy Logic – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9783030692490 (nidottu).
Kirjan kuvaus
The book includes topics, such as: path planning, avoiding obstacles, following the path, go-to-goal control, localization, and visual-based motion control. The theoretical concepts are illustrated with a developed control architecture… Näytä koko kuvaus Piilota kuvaus
The book includes topics, such as: path planning, avoiding obstacles, following the path, go-to-goal control, localization, and visual-based motion control. The theoretical concepts are illustrated with a developed control architecture with soft computing and artificial intelligence methods. The proposed vision-based motion control strategy involves three stages. The first stage consists of the overhead camera calibration and the configuration of the working environment. The second stage consists of a path planning strategy using several traditional path planning algorithms and proposed planning algorithm. The third stage consists of the path tracking process using previously developed Gauss and Decision Tree control approaches and the proposed Type-1 and Type-2 controllers. Two kinematic structures are utilized to acquire the input values of controllers. These are Triangle Shape-Based Controller Design, which was previously developed and Distance-BasedTriangle Structure that is used for the first time in conducted experiments. Four different control algorithms, Type-1 fuzzy logic, Type-2 Fuzzy Logic, Decision Tree Control, and Gaussian Control have been used in overall system design. The developed system includes several modules that simplify characterizing the motion control of the robot and ensure that it maintains a safe distance without colliding with any obstacles on the way to the target. The topics of the book are extremely relevant in many areas of research, as well as in education in courses in computer science, electrical and mechanical engineering and in mathematics at the graduate and undergraduate levels.
Kirjan tiedot
Vertaa kirjan ”Vision-Based Mobile Robot Control and Path Planning Algorithms in Obstacle Environments Using Type-2 Fuzzy Logic” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9783030692490.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Vision-Based Mobile Robot Control and Path Planning Algorithms in Obstacle Environments Using Type-2 Fuzzy Logic – hintahistoria
Seuraamme kirjan Vision-Based Mobile Robot Control and Path Planning Algorithms in Obstacle Environments Using Type-2 Fuzzy Logic hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.