
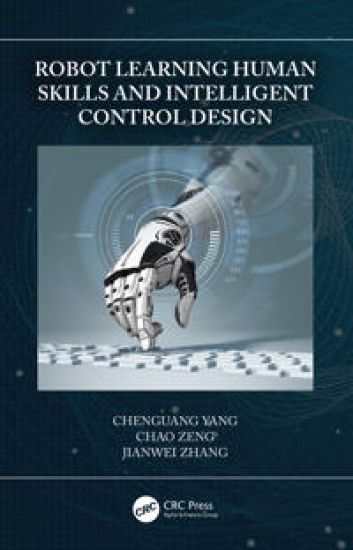
Robot Learning Human Skills and Intelligent Control Design – hinnat ja saatavuus
Kirjafiili on kirjojen hintavertailu. Löydä halvin hinta 27 kirjakaupasta. Hintavertailu koskee ISBN-tunnusta 9780367634377 (nidottu).
Muut painokset ja formaatit
Kirjan kuvaus
In the last decades robots are expected to be of increasing intelligence to deal with a large range of tasks. Especially, robots are supposed to be able to learn manipulation skills from humans. To this end, a number of learning algorithms… Näytä koko kuvaus Piilota kuvaus
In the last decades robots are expected to be of increasing intelligence to deal with a large range of tasks. Especially, robots are supposed to be able to learn manipulation skills from humans. To this end, a number of learning algorithms and techniques have been developed and successfully implemented for various robotic tasks. Among these methods, learning from demonstrations (LfD) enables robots to effectively and efficiently acquire skills by learning from human demonstrators, such that a robot can be quickly programmed to perform a new task. This book introduces recent results on the development of advanced LfD-based learning and control approaches to improve the robot dexterous manipulation. First, there's an introduction to the simulation tools and robot platforms used in the authors' research. In order to enable a robot learning of human-like adaptive skills, the book explains how to transfer a human user’s arm variable stiffness to the robot, based on the online estimation from the muscle electromyography (EMG). Next, the motion and impedance profiles can be both modelled by dynamical movement primitives such that both of them can be planned and generalized for new tasks. Furthermore, the book introduces how to learn the correlation between signals collected from demonstration, i.e., motion trajectory, stiffness profile estimated from EMG and interaction force, using statistical models such as hidden semi-Markov model and Gaussian Mixture Regression. Several widely used human-robot interaction interfaces (such as motion capture-based teleoperation) are presented, which allow a human user to interact with a robot and transfer movements to it in both simulation and real-word environments. Finally, improved performance of robot manipulation resulted from neural network enhanced control strategies is presented. A large number of examples of simulation and experiments of daily life tasks are included in this book to facilitate better understanding of the readers.
Kirjan tiedot
Vertaa kirjan ”Robot Learning Human Skills and Intelligent Control Design” hintoja
Vertaa tuotteen hintaa ja arvioitua kokonaishintaa toimitettuna. Kaikki hinnat koskevat ISBN-tunnusta 9780367634377.
Hintoja ei päivitetty automaattisesti. Voit hakea ajantasaiset hinnat painamalla Hae hinnat.

Booky

Suomalainen

Kansallinen Kirjakauppa

Prisma

Finlandia Kirja

Fantasiapelit

Vinhan kirjakauppa

CDON

Kustantamo S&S
Kennys.ie

Kristillinenkirjakauppa.fi
Sacrum

Adlibris

BookOutlet.fi

Kirja.fi

Rosebud
Tälle kirjalle ei ole tällä hetkellä vahvistettua hintaa. Tarkista tilanne myöhemmin uudelleen.
Hintoja ei ole vielä päivitetty.
Hälytys tallennettu!
Ilmoitamme, kun hinta laskee.
Saat sähköpostin, kun hinta laskee asettamaasi rajaan tai sen alle.
Robot Learning Human Skills and Intelligent Control Design – hintahistoria
Seuraamme kirjan Robot Learning Human Skills and Intelligent Control Design hintakehitystä kirjakaupoissa. Taulukosta näet viime kuukausien alimmat hinnat.
Alin hinta kauppoittain
Kunkin kaupan alin hinta viimeisten 90 päivän aikana.
Hintahistoriaa ei ole vielä kerätty tälle kirjalle.
Hinnat ilman toimituskuluja.